54 / Aviation & Aerospace
Autonomous AI Drone with Natural-Language Missions
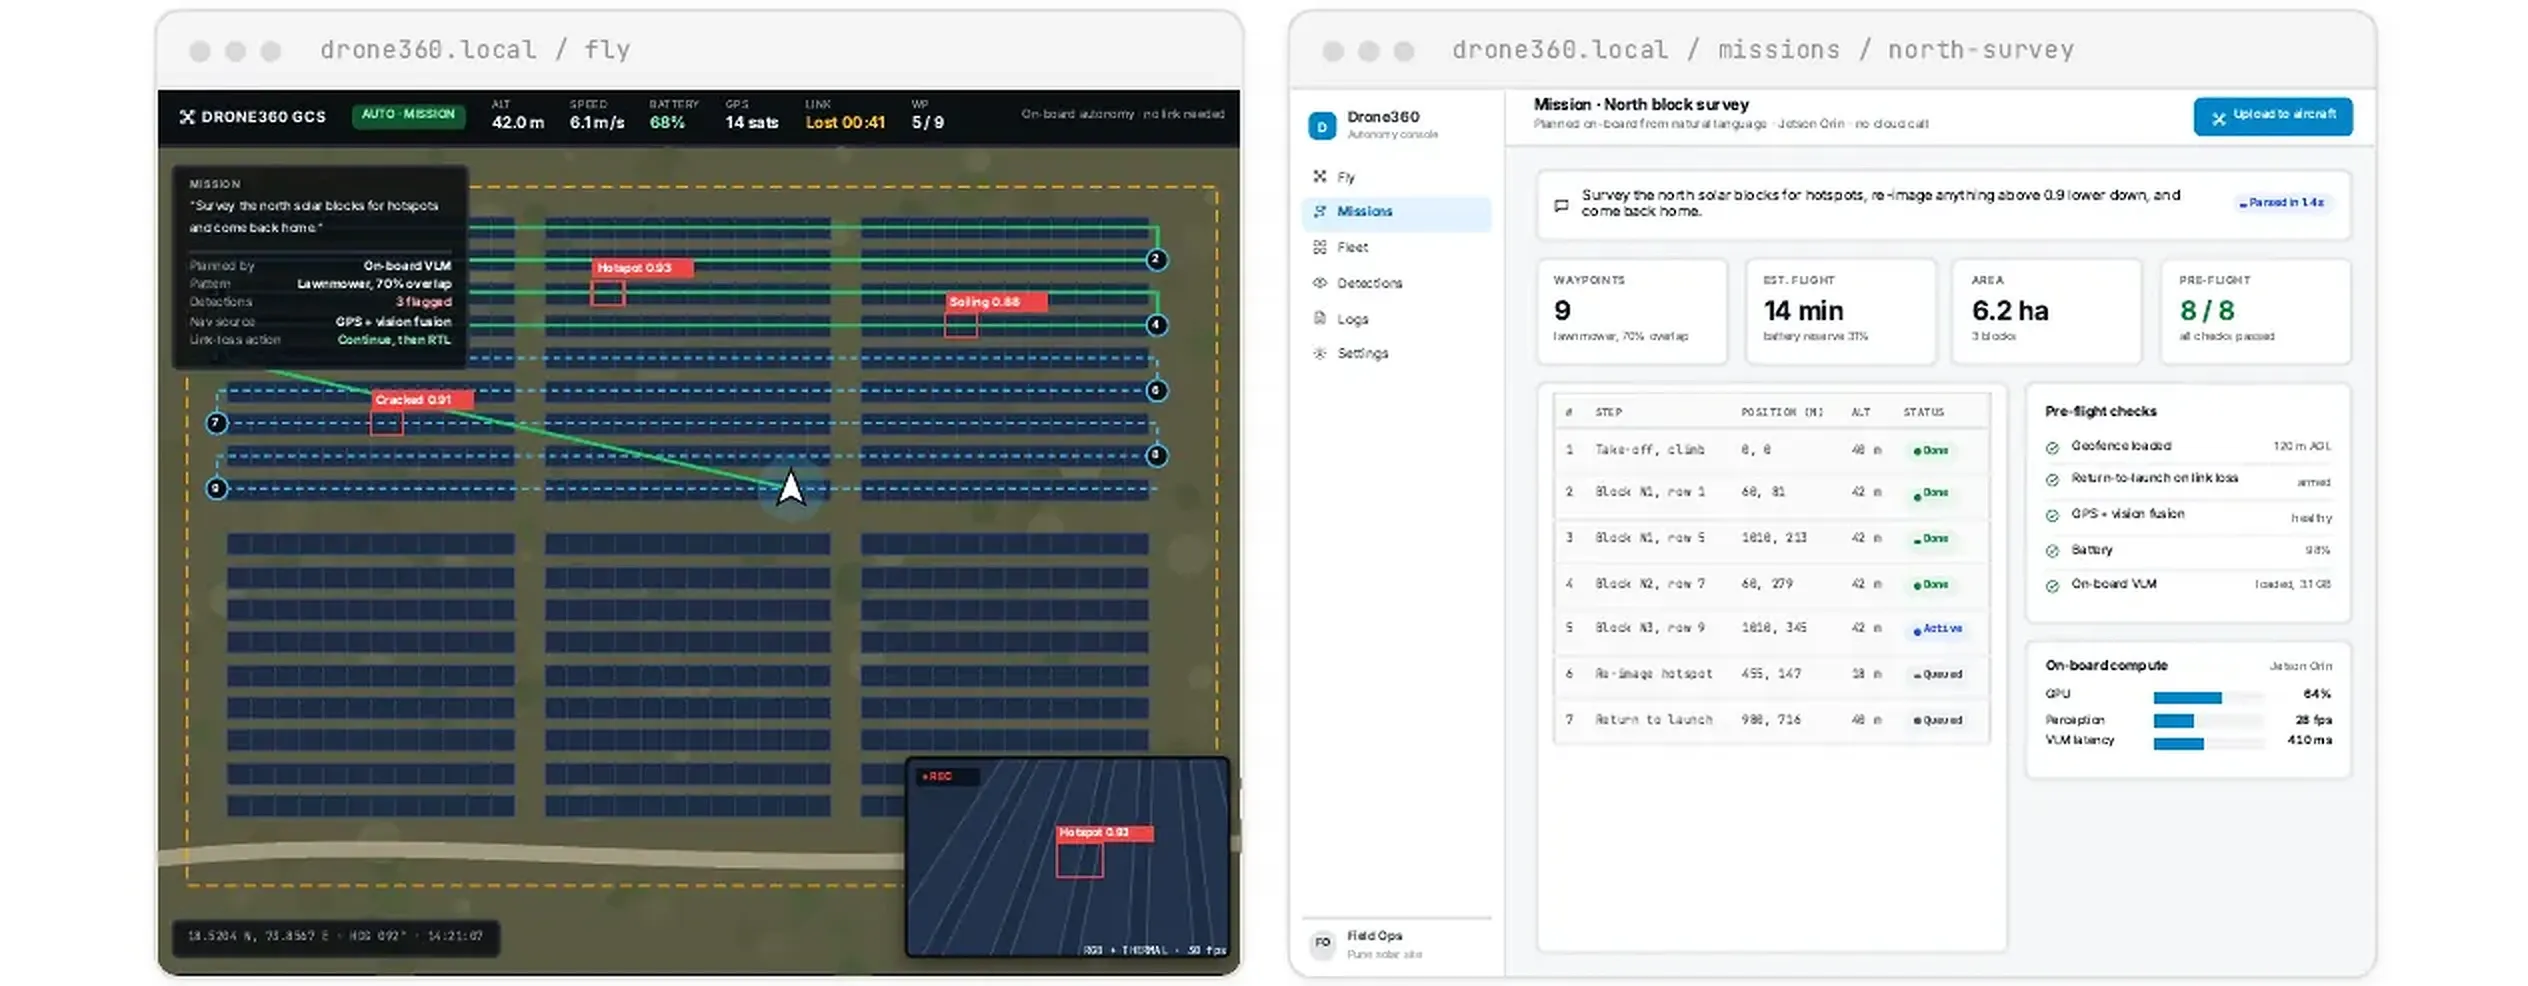
We built the full brain-and-body stack for a drone that takes missions in plain language and flies them on its own, keeping the intelligence on-board so it works where there's no pilot and no cloud link.
- Built by
- 360 Labs R&D
- Stack & approach
- AutonomyOn-Board VLMSensor FusionEdge Compute
The problem
Drones that need a pilot or a cloud link can't operate in GPS-poor or disconnected environments, exactly the conditions where autonomous inspection is most valuable.
Solution & architecture
A full autonomy stack: flight control, a companion computer running perception and an on-device vision-language model for natural-language missions, sensor fusion that moves from GPS to GPS-plus-vision and optical flow, and an architecture built for on-board visual SLAM. Geofencing and return-to-launch on link loss are built in; it was delivered as a complete 16-week architecture and working monorepo.
Why it is built this way
Intelligence on-board
Perception and VLM run on the drone
Works disconnected
No pilot, no cloud link needed
Fail-safe built-in
Geofence and return-to-launch on link loss